Why Simple Cosine Similarity Fails Hiring — And What We Built Instead
Matching is reciprocal and uncertain. Jobrov combines 4-route Reciprocal Rank Fusion (RRF), ESCO typed skill graphs, non-overlapping chronology math, tri-state constraint gates, and bounded harmonic fit intervals H(E,C).
Launch Interactive Matching Lab (Sara Demo + 500-Pair Benchmark)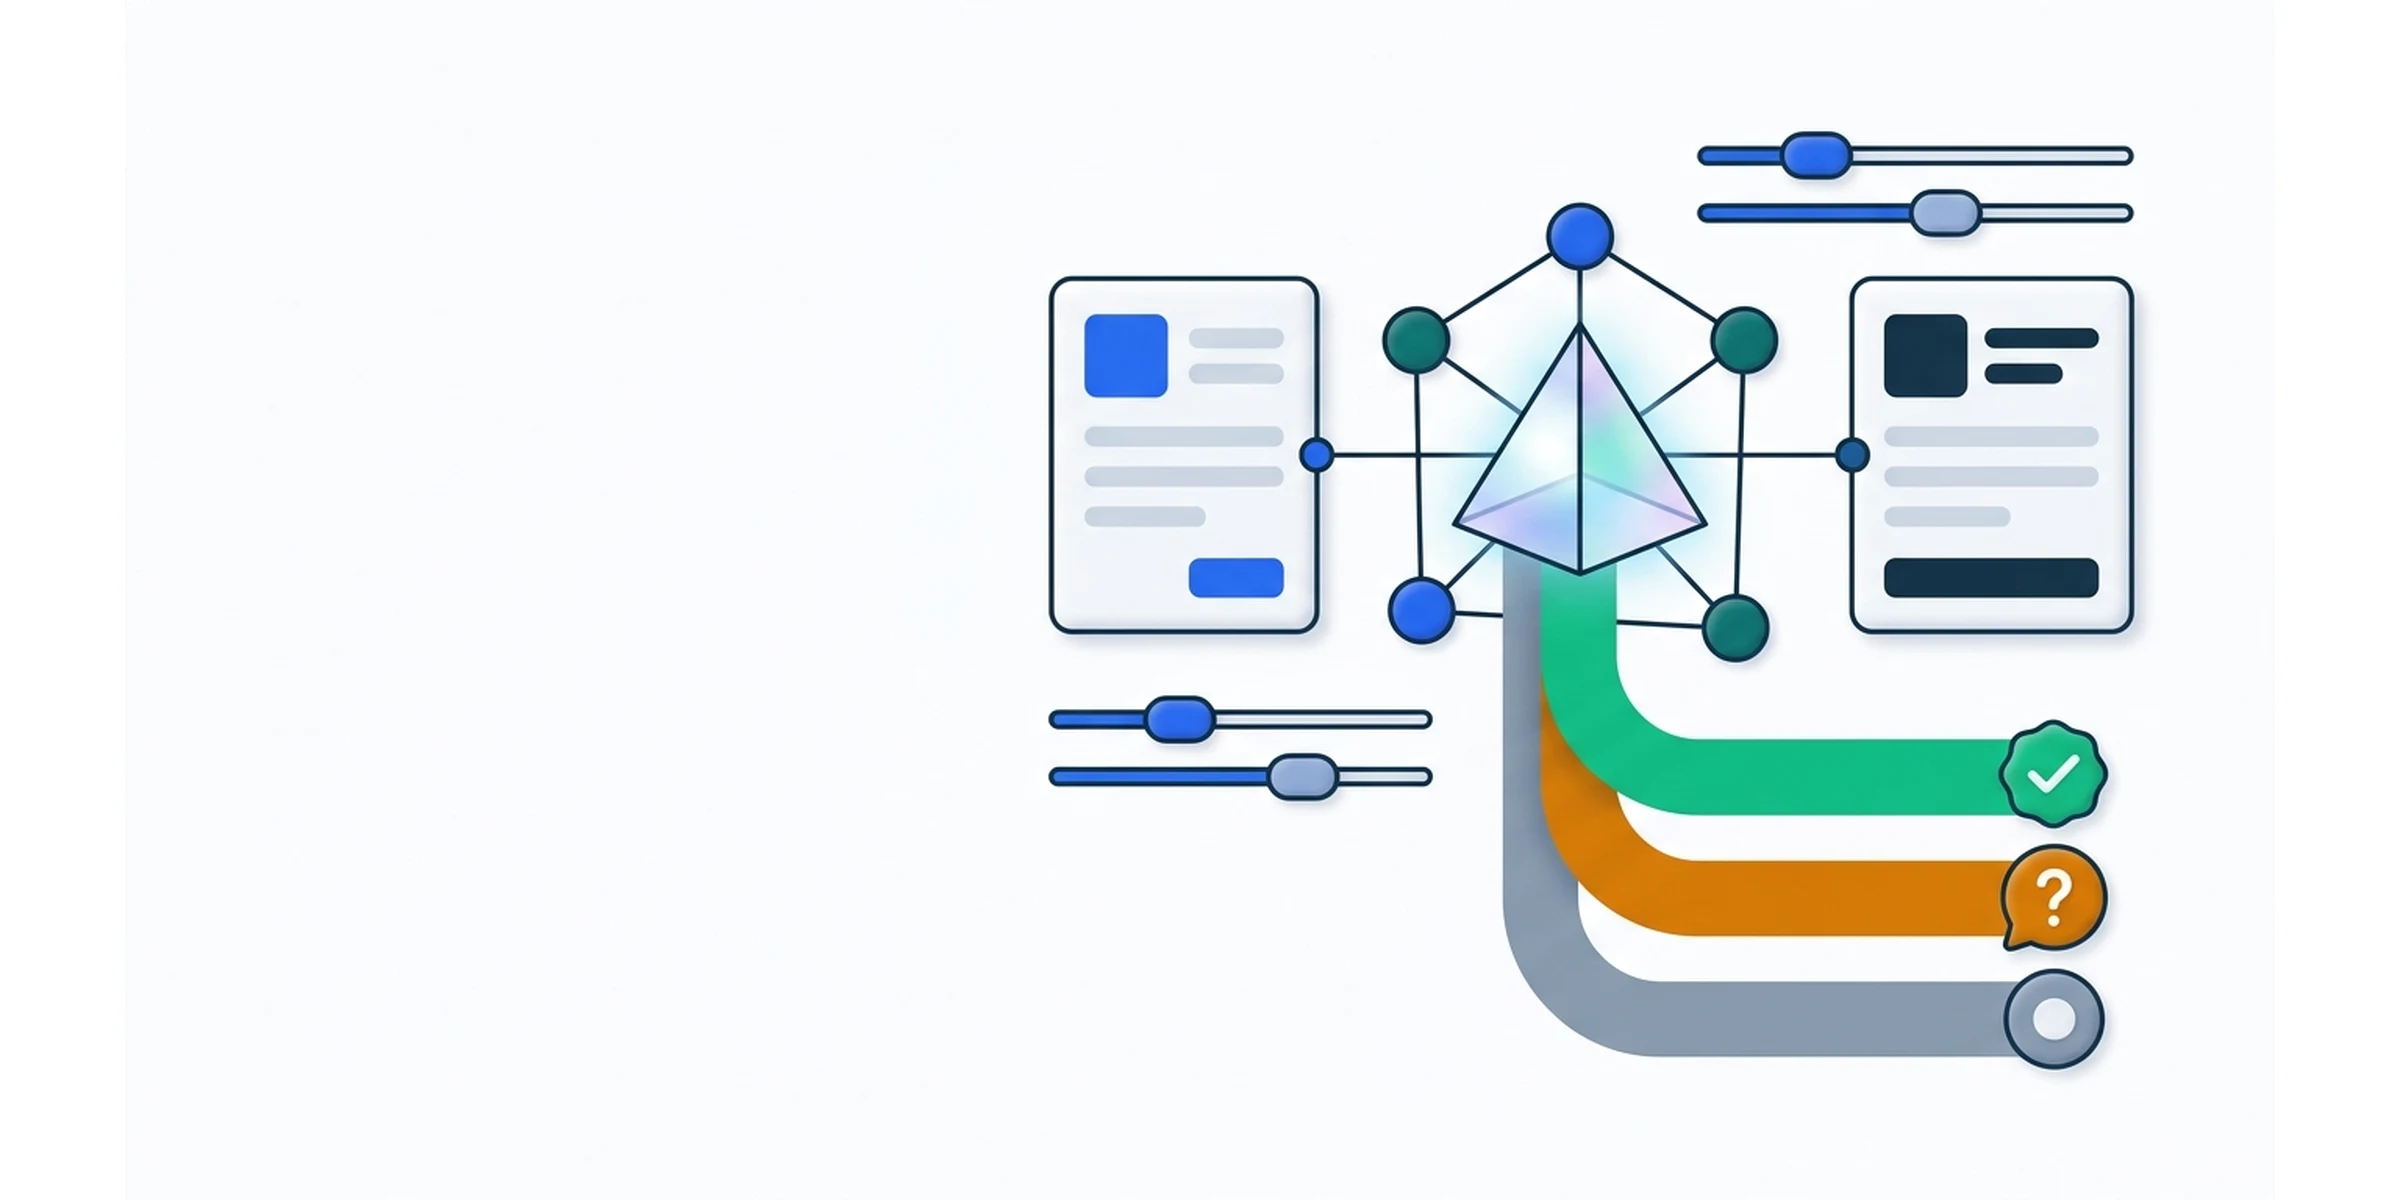
Ten Architectural Pillars of the Jobrov Matching Classifier
1. ESCO Typed Vocabulary
Typed skill edges: Equivalent (1.0), Narrower (0.85), Broader (0.80), Prerequisite (0.65), and Related (0.45 transferable workflow — never conflated with holding a vendor certification).
2. Verbatim Span Evidence
Every extracted claim cites exact page and character offsets (CharStart..CharEnd) and separates extraction confidence from candidate competence.
3. Non-Overlapping Chronology
Concurrent work intervals [start, end] are merged via interval union before summing duration so two overlapping jobs in one calendar year equal 1.0 year, never 2.0.
4. 4-Route RRF Retrieval
Combines Lexical BM25, Dense Task Vectors, ESCO Taxonomy IDs, and Adjacent-Role Transfer via Reciprocal Rank Fusion: sum(1 / (60 + rank_i)).
5. Reciprocal Fit H(E,C)
Computes Employer Fit E and Candidate Fit C as bounded uncertainty intervals [Lower, Upper], merged via H(E,C) = 2EC/(E+C).
6. Three Explicit Lanes
Splits results into Eligible (Strong Evidence), Clarification Needed (TriState.Unknown), and Stretch/Conflict — blocking auto-apply on any unresolved constraint.